S1 / UNDERWATER ROV
LINKDEEP S1
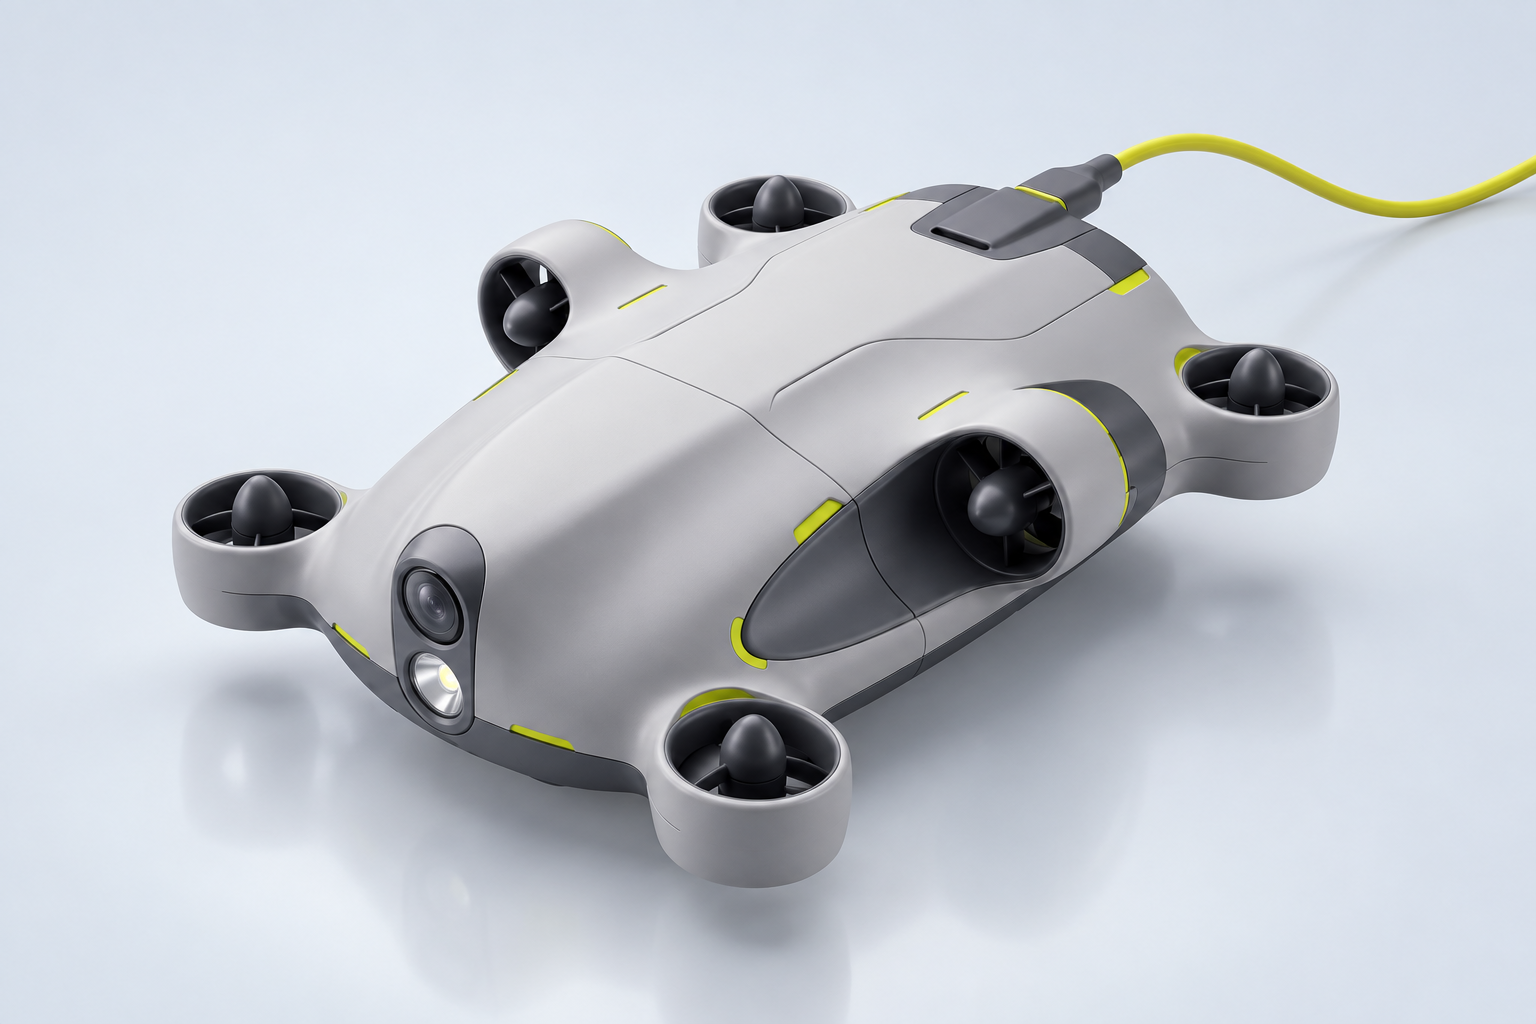
A small vehicle with a six-thruster layout. LINKDEEP S1 is designed around underwater observation and light inspection, connecting the vehicle to shore-based operation with a clear task in mind.
For research observation, near-shore environmental records and routine underwater viewing. Start with the subject and the purpose of the records, then bring site conditions, equipment choices and the workflow together.
BUILT AROUND THE TASK
A platform with a purpose.
Start with a smaller platform
The S1 combines a small vehicle body with six thrusters. Select the equipment around the observation area, launch point and available working space, so the platform fits the scale of the task.
Explore below. Operate from shore.
A tether connects the robot to its shore controller. Planning the launch point, tether route and observation route together gives the field team a clear structure for the operation.
Choose equipment for the question
Start with what needs to be observed, recorded and understood, then work through the equipment selection. Consistent information requirements make sense for both a single observation and a sequence of visits.
FORM. PERSPECTIVE. DETAIL.
A different angle. A closer look.
Explore the design from the front, in profile and from above.
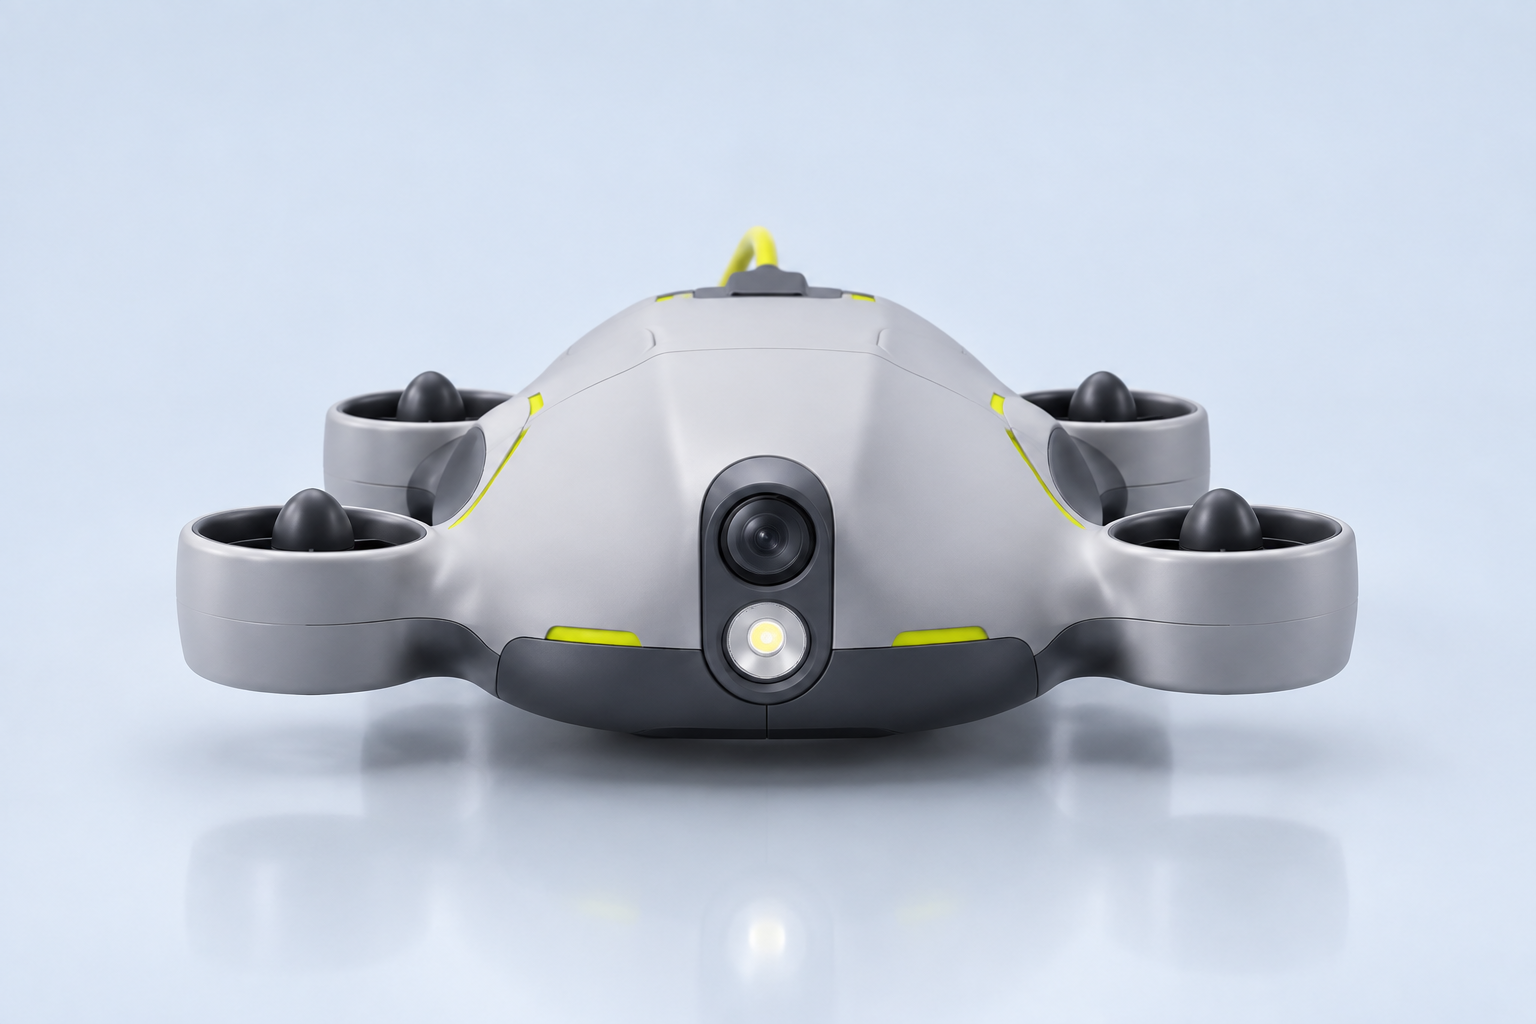
Front view
The forward camera window, lighting and front silhouette.
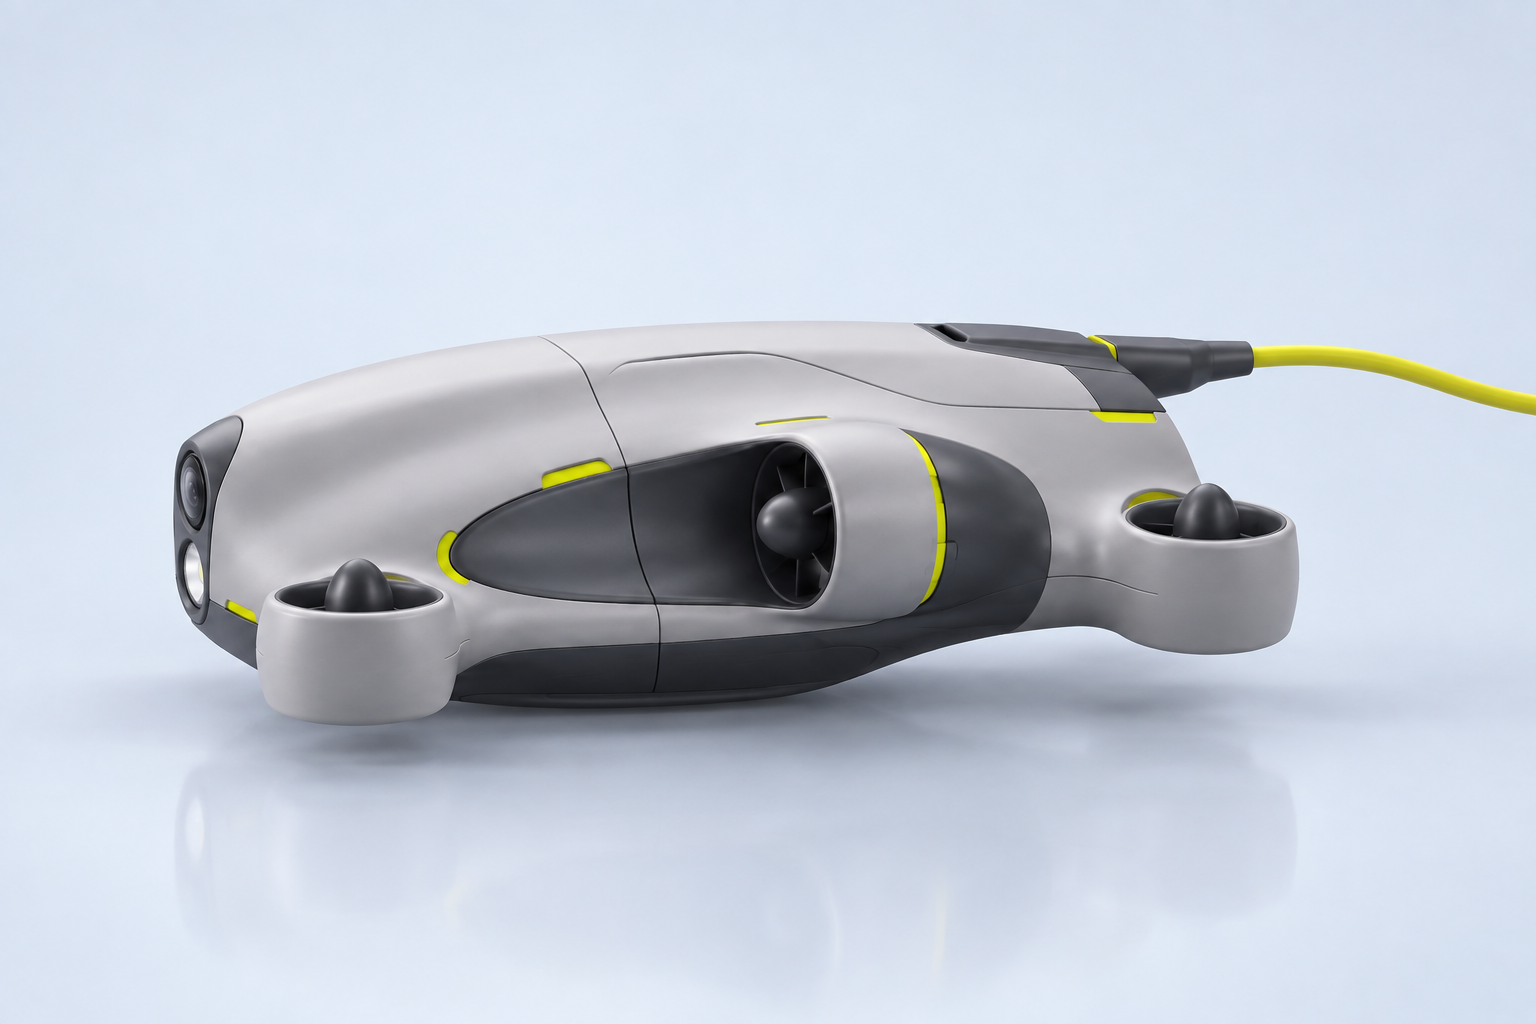
Side profile
A side-on look at the curved shell and propulsion units.
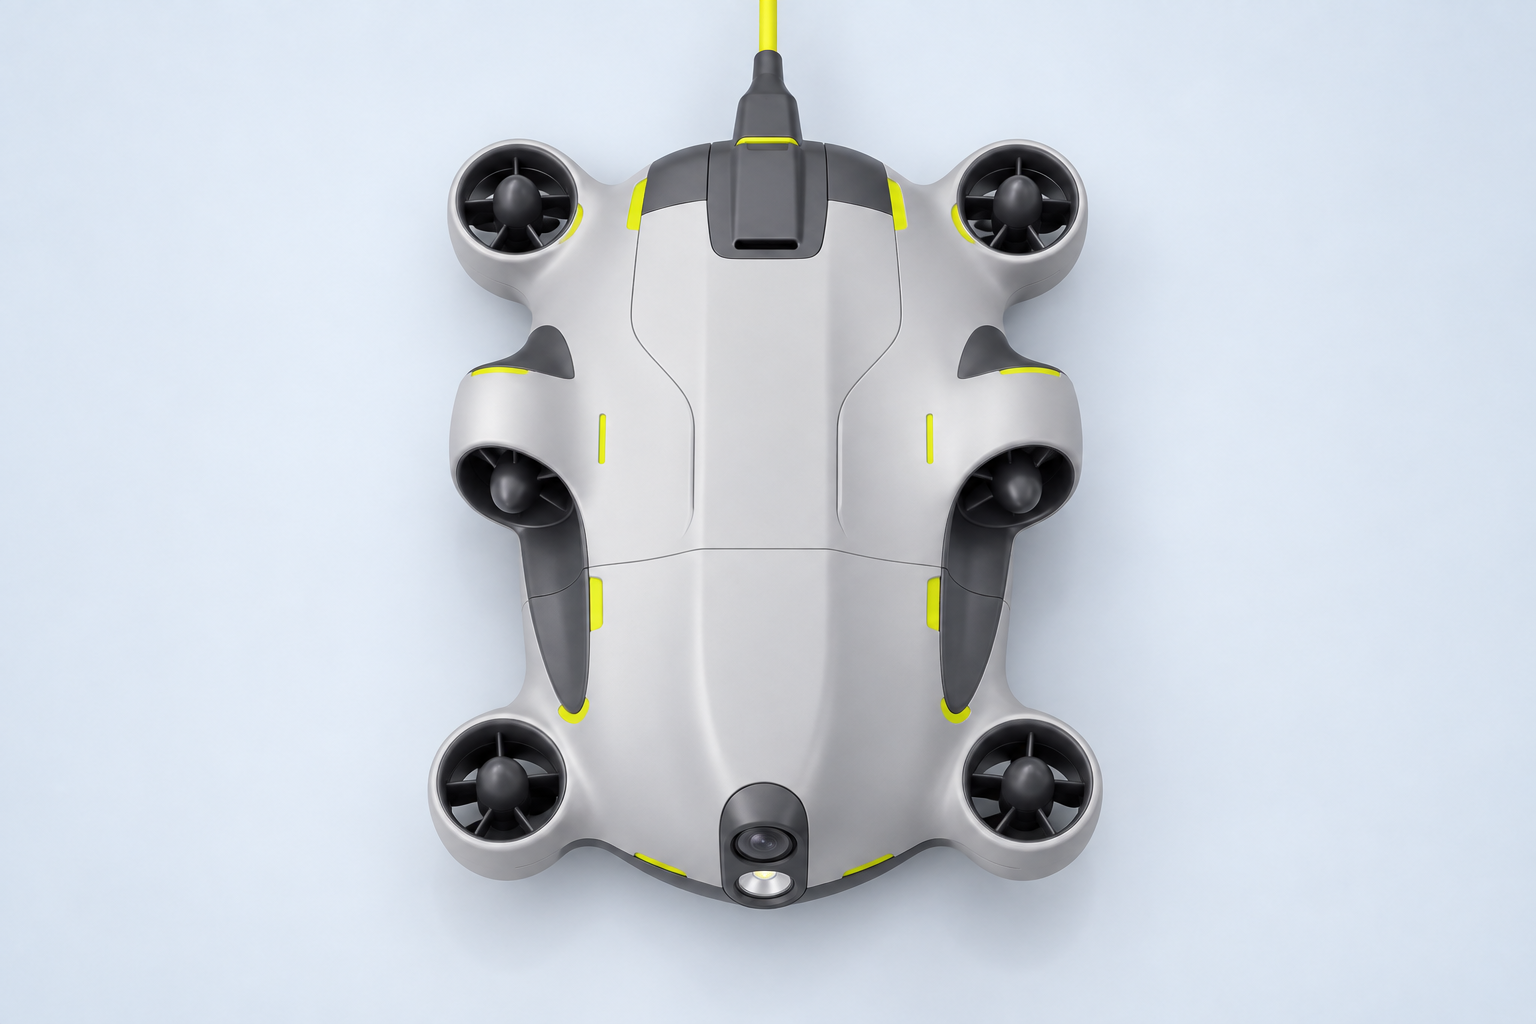
Top view
The overall outline, service cover and thruster layout from above.
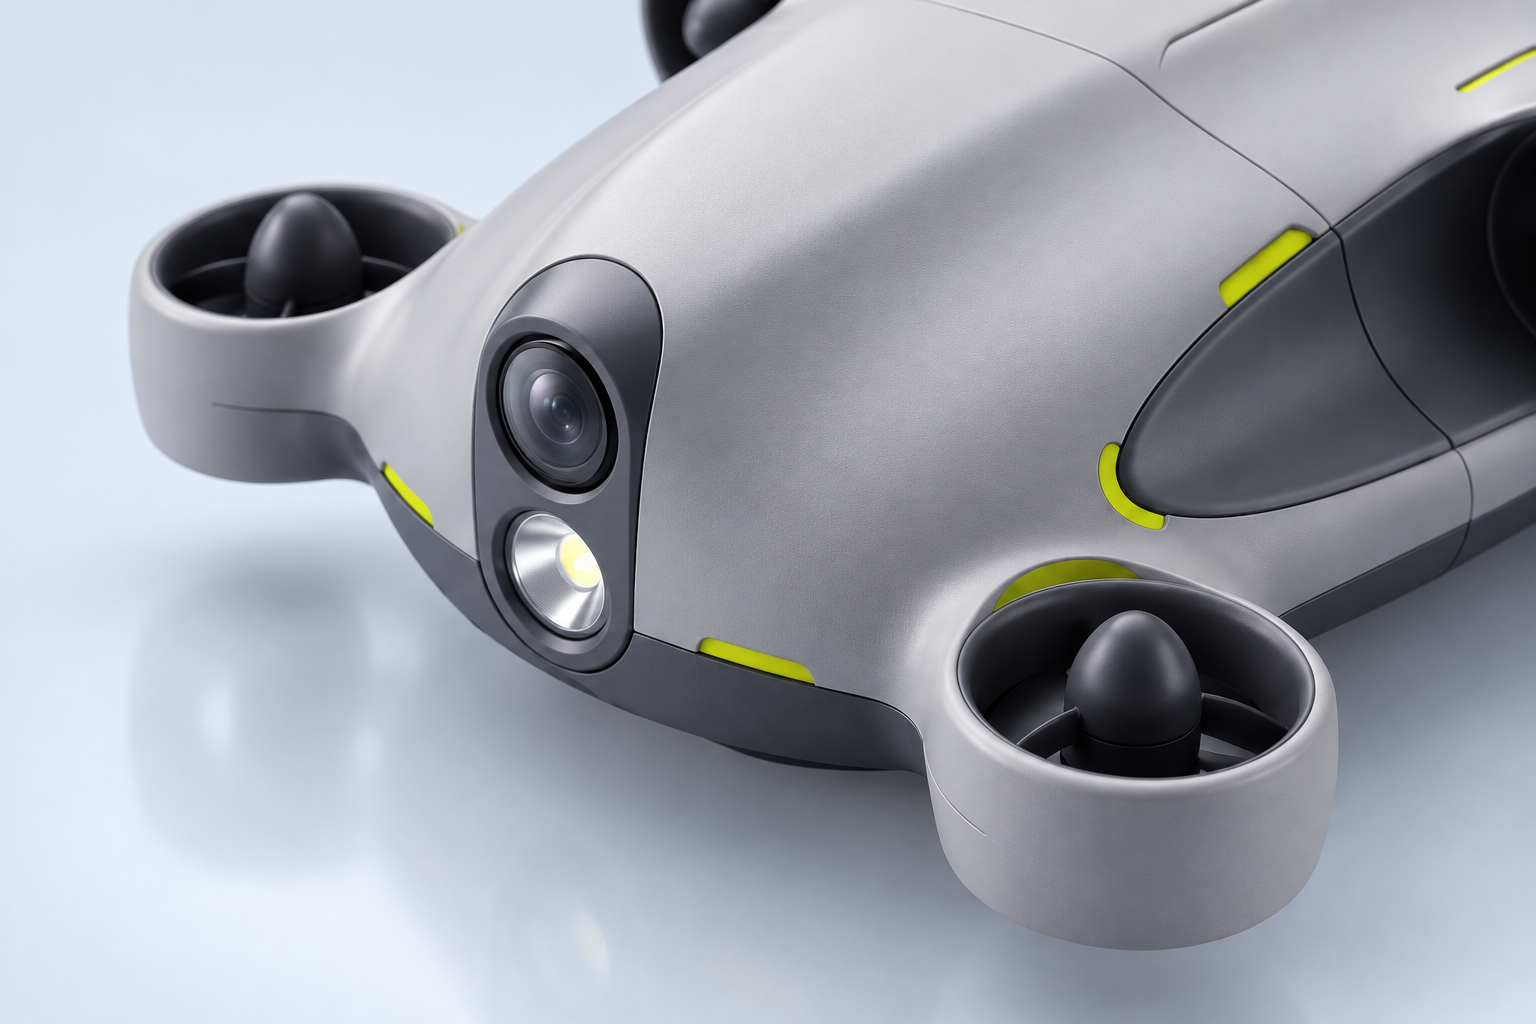
A closer look
A close-up of the camera, lighting and thruster shroud.
Product renderings · Explore the body shape, thruster layout and front assembly from multiple perspectives.
Platform at a glance
| Model | LINKDEEP S1 |
|---|---|
| Size class | Small |
| Thruster count | 6 |
| Vehicle connection | Tether to a shore controller |
| Operator station | Shore-based controller |
| Product focus | Observation and light inspection |
Platform selection and sensing requirements go hand in hand with the environment, observation targets and field workflow. Contact us to discuss the configuration for your task.