M1 / UNDERWATER ROV
LINKDEEP M1
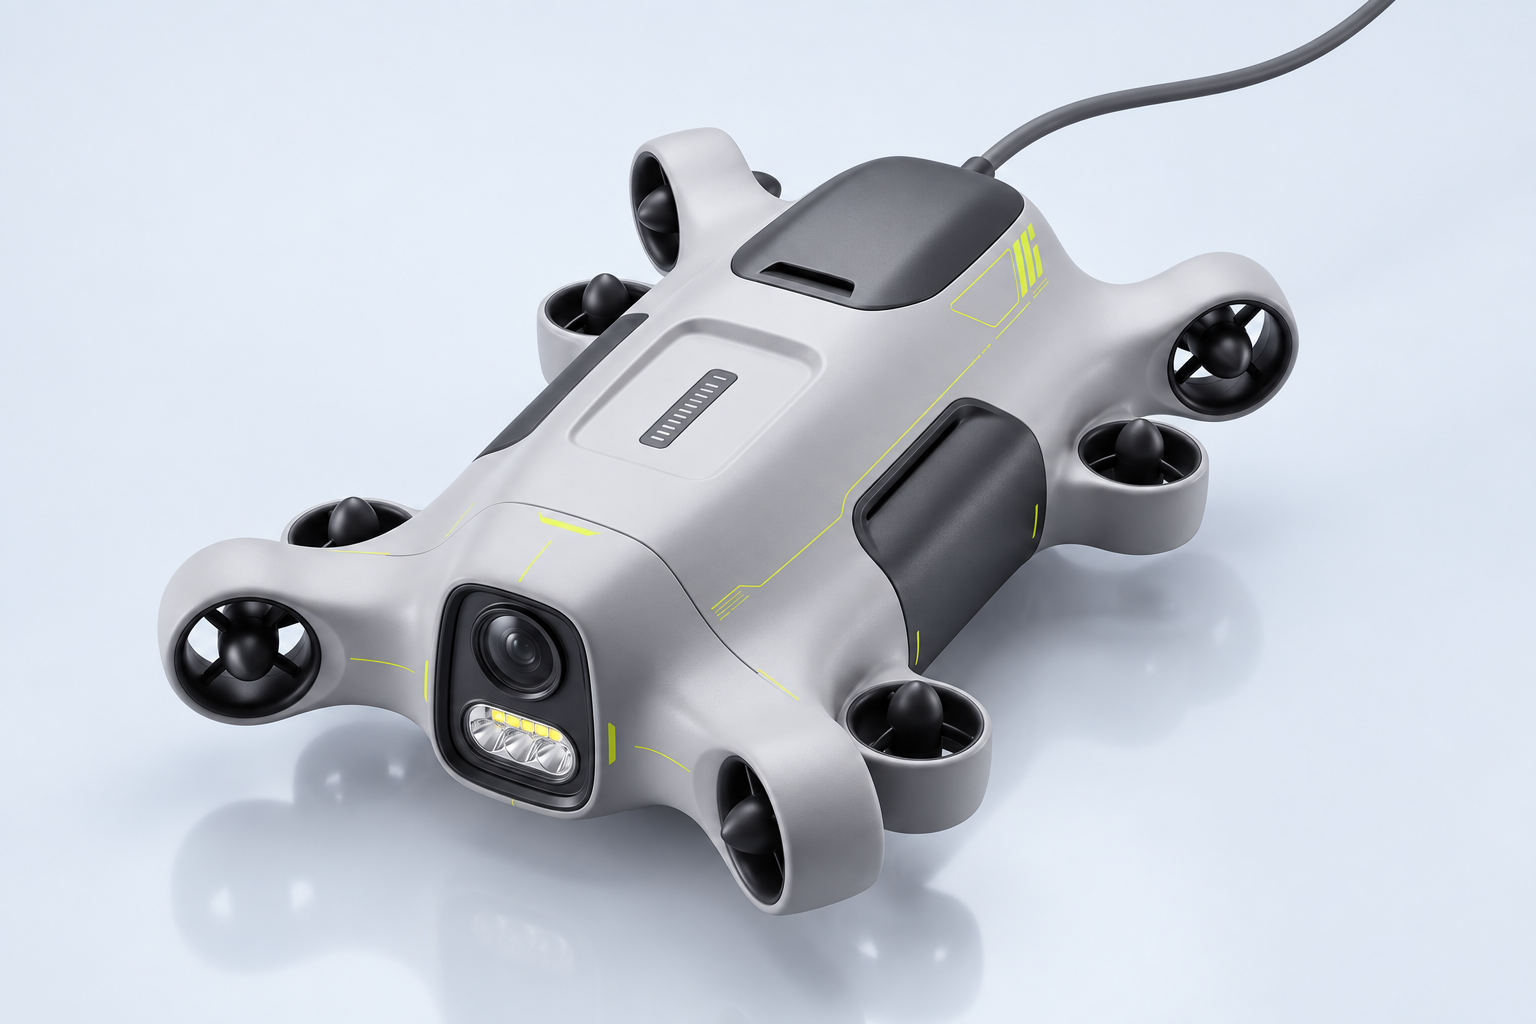
A medium vehicle with an eight-thruster layout. LINKDEEP M1 focuses on underwater asset inspection and engineering observation, bringing equipment selection and field priorities into an organized task.
For observation tasks involving water infrastructure, bridges, ports and submerged structures. Select equipment around access conditions and inspection priorities, with the operation and its records considered together.
BUILT AROUND THE TASK
A platform with a purpose.
A platform focused on engineering tasks
The M1 brings a medium body and eight-thruster layout to engineering observation. Equipment selection considers the whole task, from the scale of the asset and inspection points to launch conditions.
Connect the vehicle and the field team
The tether connects the robot to a shore controller, keeping the operator station above water. Clear roles for vehicle operation, tether handling and field notes help organize the work.
From inspection points to useful records
Build the project conversation around the asset, inspection priorities and required records. Planning the observation sequence and record format connects underwater work with subsequent maintenance decisions.
FORM. PERSPECTIVE. DETAIL.
A different angle. A closer look.
Explore the design from the front, in profile and from above.
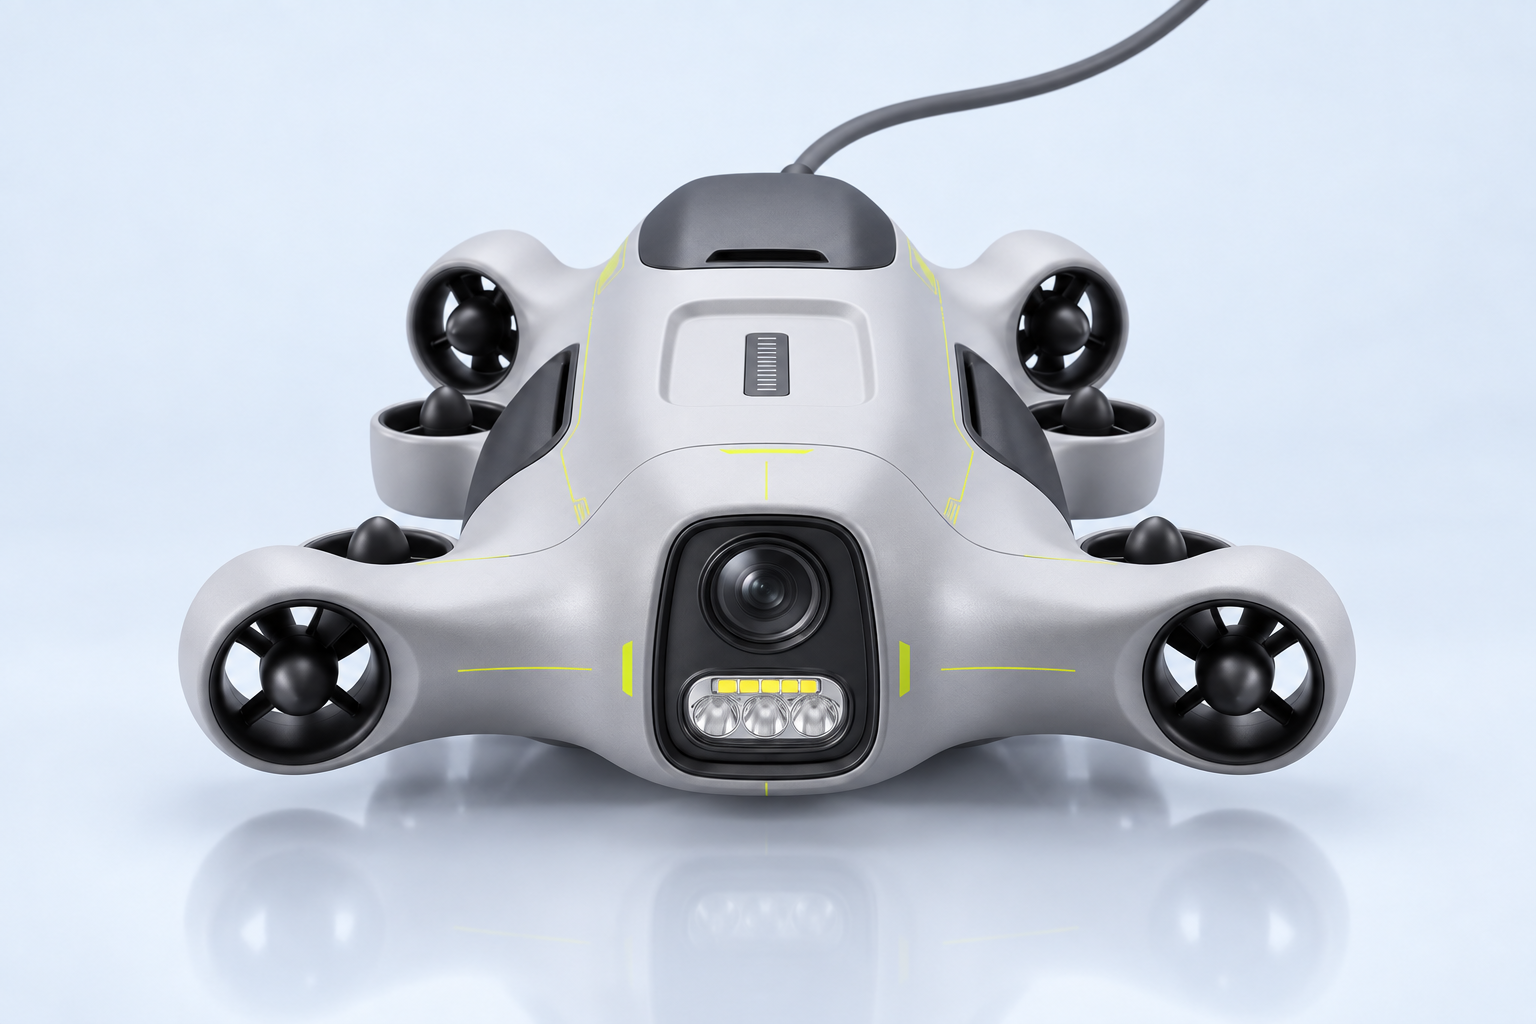
Front view
The forward camera window, lighting and front silhouette.
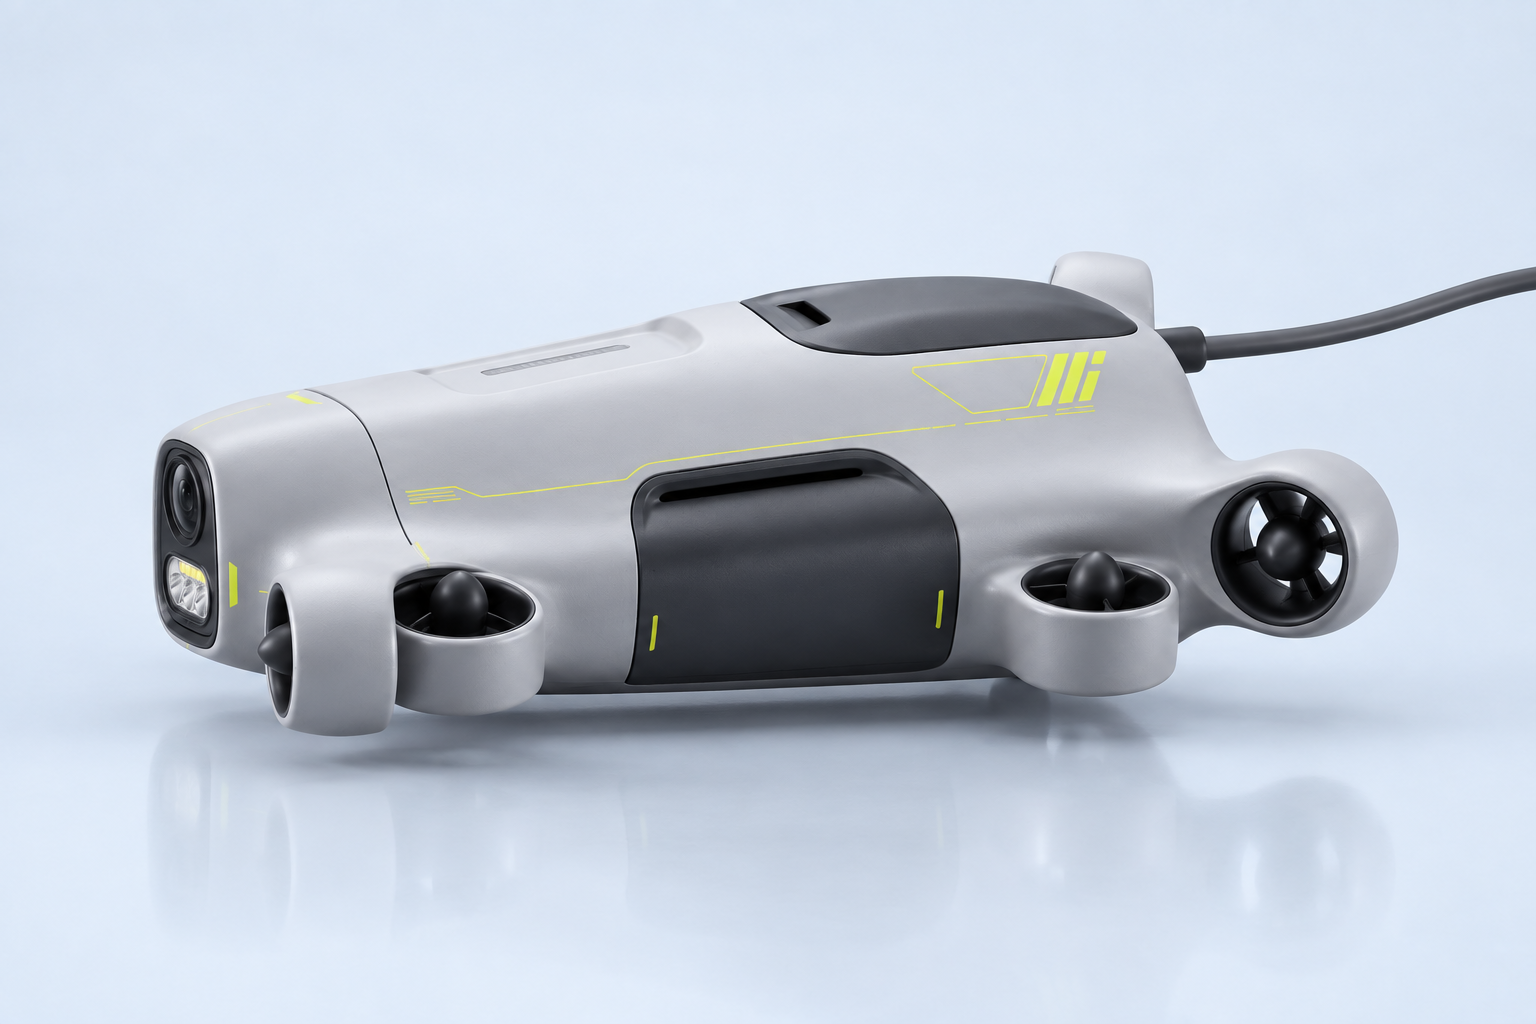
Side profile
A side-on look at the curved shell and propulsion units.
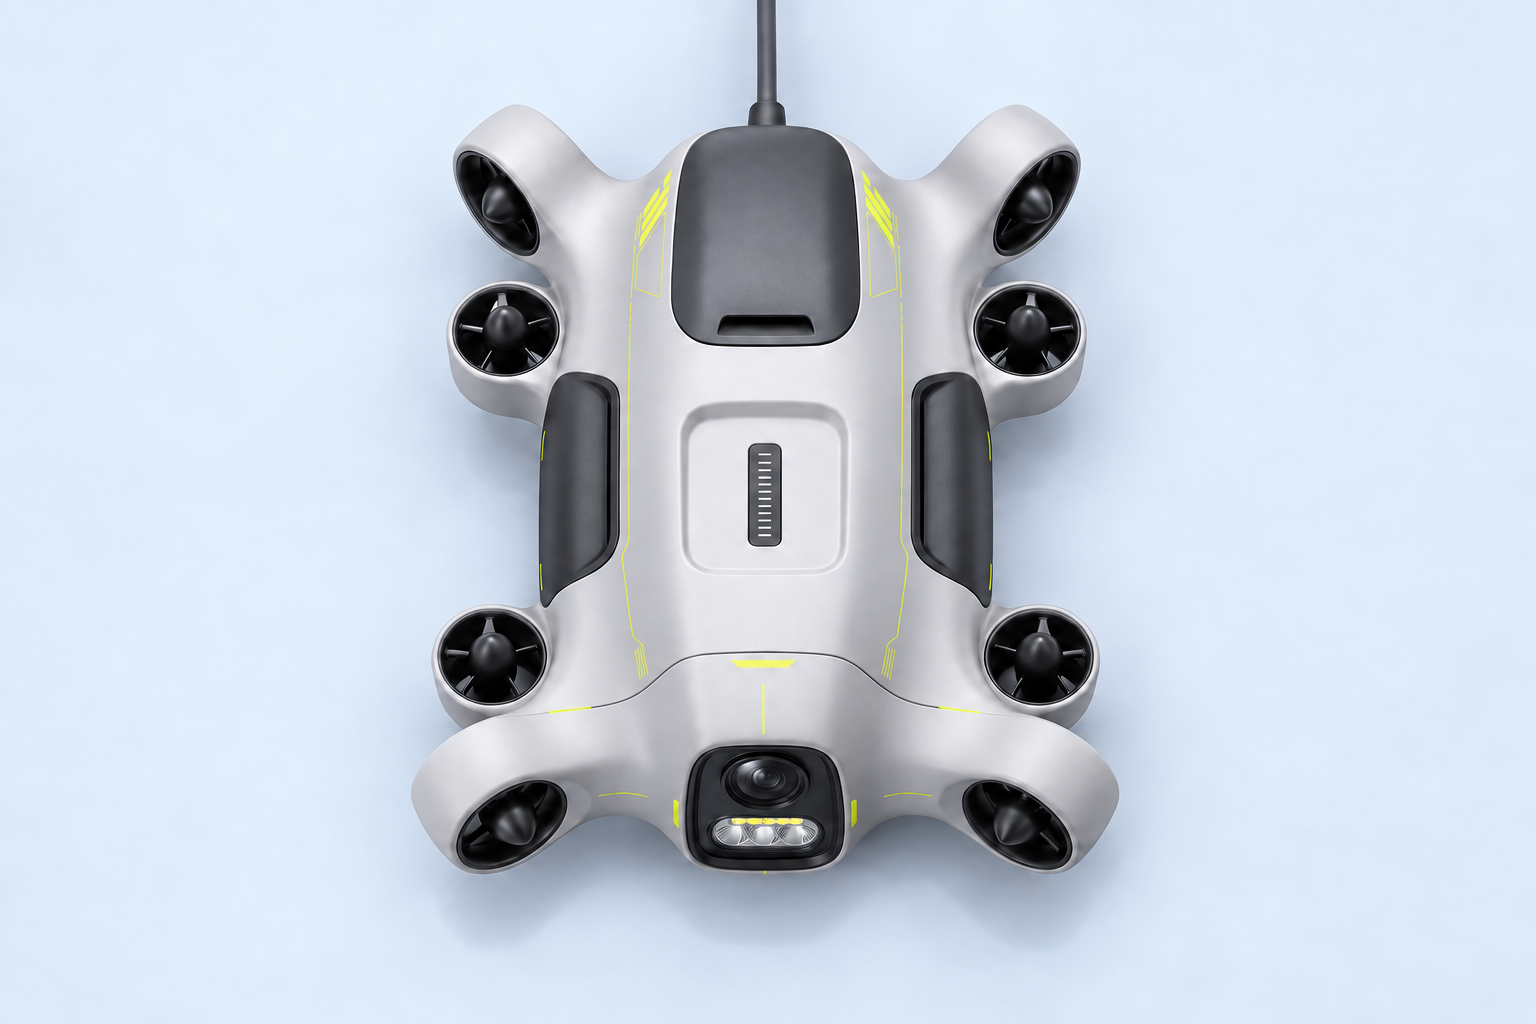
Top view
The overall outline, service cover and thruster layout from above.
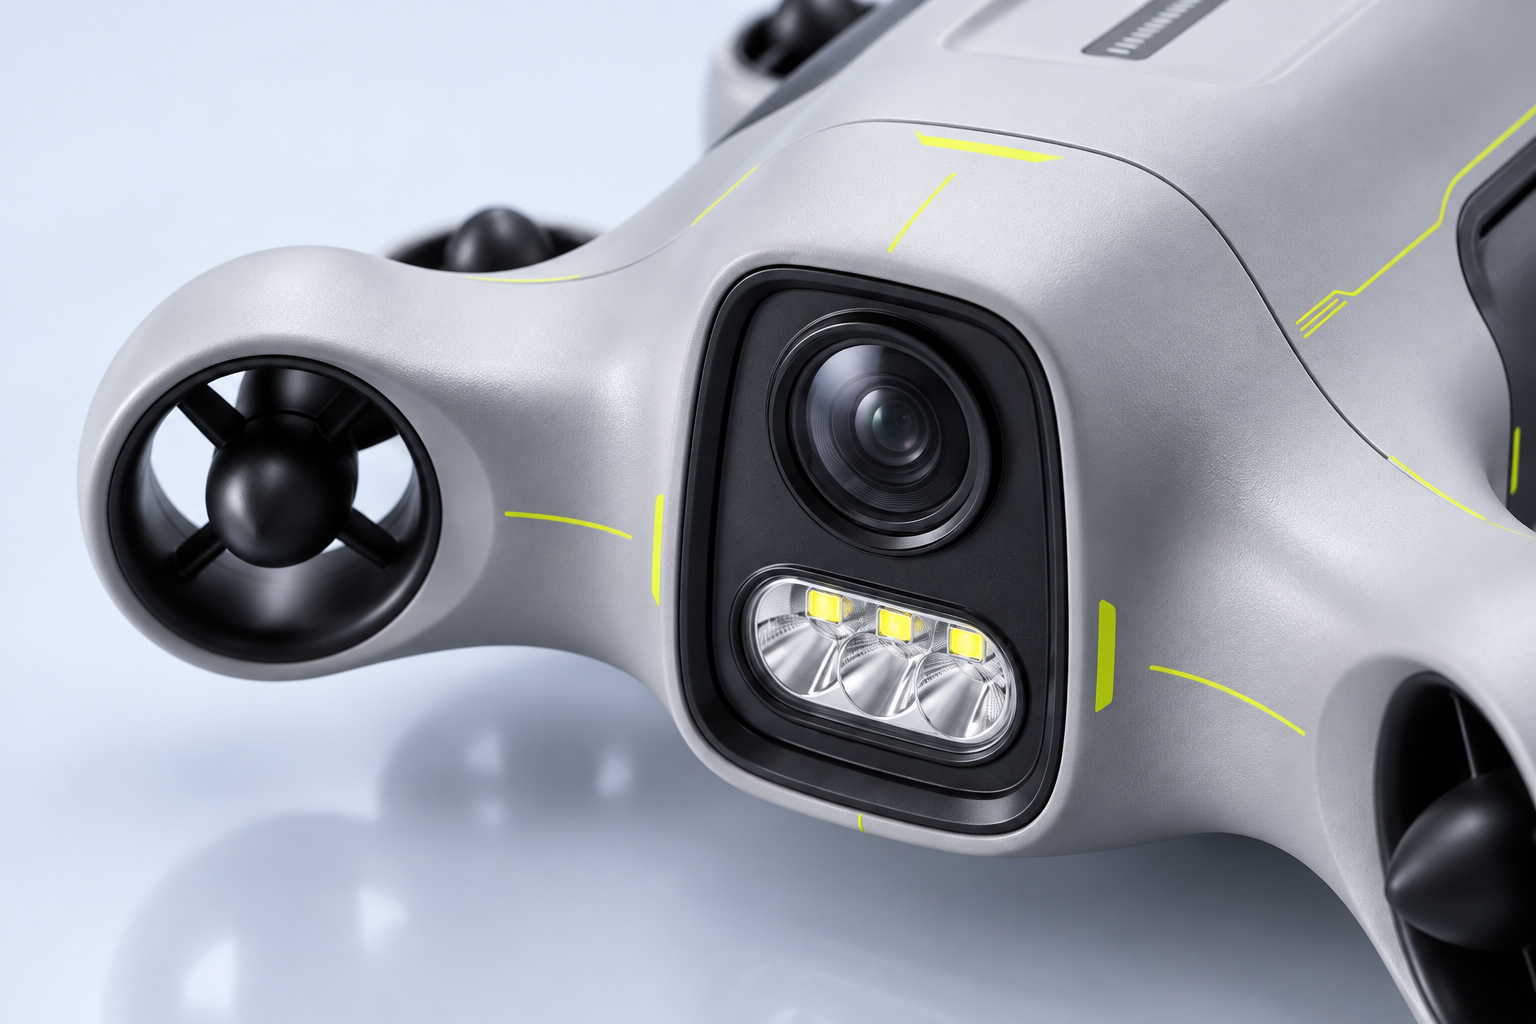
A closer look
A close-up of the camera, lighting and thruster shroud.
Product renderings · Explore the body shape, thruster layout and front assembly from multiple perspectives.
Platform at a glance
| Model | LINKDEEP M1 |
|---|---|
| Size class | Medium |
| Thruster count | 8 |
| Vehicle connection | Tether to a shore controller |
| Operator station | Shore-based controller |
| Product focus | Asset inspection and engineering observation |
Platform selection and sensing requirements go hand in hand with the environment, observation targets and field workflow. Contact us to discuss the configuration for your task.